Matching coherent shell: temporary physical boot
2026-10-01. Evidence classes: reserved physical-board serial boot, native
Wayland capture, and camera observation. Real-finger navigation and ordinary
autoboot were unverified at this capture. Real-finger navigation was later
accepted in operator-navigation.json; ordinary autoboot remains open.
This capture is not a persistent installation.
The selected p1a1hz… system and its 03zyl0… vendor kernel boot successfully
through the same CR-only manual-loading mechanism used in the earlier trial.
serial-result.json records each exact loaded file’s bytes, SHA256 and in-memory
CRC32, then the actual command line, selected system/kernel links, unchanged
persistent profile, boot ID and all three active shell services. The load CRC
is the proof of which Image was executed; a /run/booted-system/kernel link
alone cannot distinguish manually loaded kernels.
python3 tools/coherent-shell-board-stage.py prepare /var/lib/k230/coherent-boot/p1a1hz9n8s4g8qyr55ffl3dzbnjgqwr8-20261001
python3 tools/coherent-shell-board-boot.py \
  --candidate /nix/store/pnci1pzsca9f45mfyakcrzyk7yx2ad42-k230-coherent-shell-boot-files \
  --state ~/tmp/k230-coherent-boot-board/state.json \
  --output ~/tmp/k230-coherent-boot-board/candidate
python3 tests/test_coherent_shell_board_boot.py
python3 tests/test_rvv_board_boot.py
The first command runs on the board, after the four inspected boot files,
closure path list, manifest and stage tool have been delivered over the private
runtime transport. The other commands run on the host. staged-state.json is
the captured board preparation report. All 1,158 selected-system closure paths
are registered on the board, checked against its recursive closure, and
protected by a GC root. All eight normal boot/selector files were copied to
<stage>/backup on the existing root filesystem before the trial. Original
profile, stage 1, root layout and boot files were preserved. The bootstrap
/nix-path-registration file remained absent.
The controller inspected bootcmd, blinux and preboot without saveenv;
the response hash is recorded and its raw contents stay in the private console
log. Five loads from root partition mmc 1:2 were checked before volatile env
import and bootm 0x8000000 0x9000000 0x8400000. The unchanged OpenSBI wrapper
was loaded from the protected backup. controller-used.py is the exact source
snapshot whose SHA256 matches the report; it is provenance, not a standalone
entrypoint. The landed tool additionally rejects a changed profile, mismatching
kernel/init identity or inactive shell services, all of which match in this
actual report. Five staged-plan tests and five shared UART-protocol tests pass.
After boot, explicitly hiding the transient Rust surface and issuing
swaymsg 'card_shell home' produced visible Home. A second on-board stage.py check passed before grim capture: the normal files/profile and registered
closure were still intact. The earlier ambiguous dark-panel result was not
reproduced here. This does not identify its root cause or establish a kernel
driver defect.
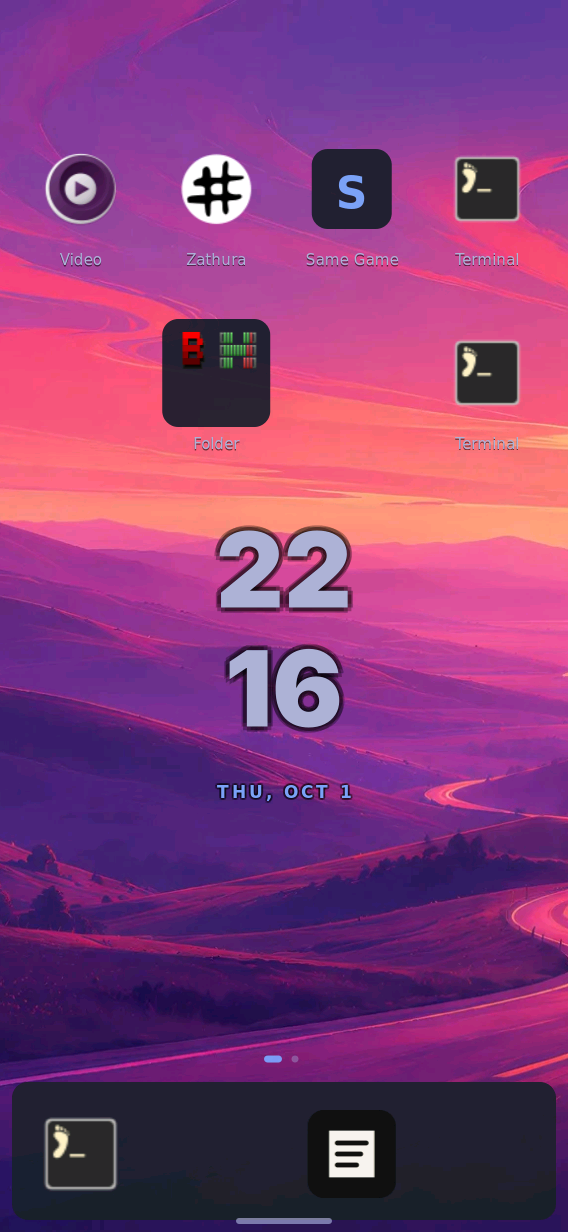
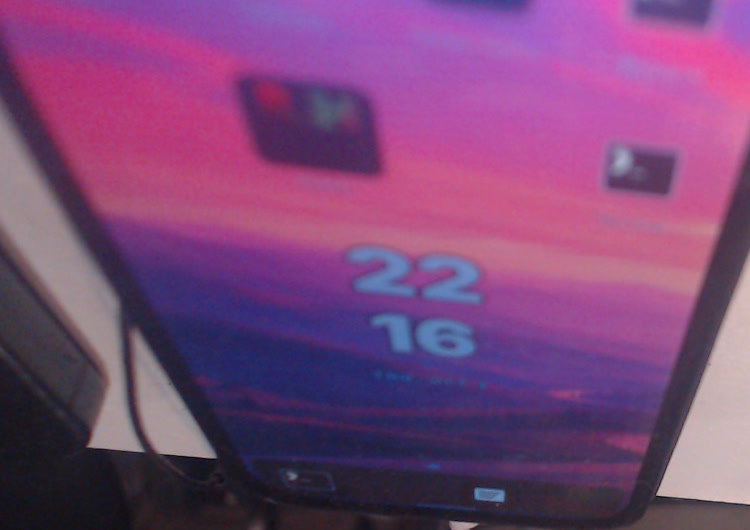
The camera photograph shows the visible part of the panel; the device extends outside the camera frame. Its exact capture command was:
ffmpeg -nostdin -hide_banner -loglevel error -f v4l2 -input_format mjpeg \
  -video_size 1280x720 -i /dev/video0 \
  -vf 'crop=750:530:530:185,transpose=2,transpose=2' \
  -frames:v 1 -q:v 2 -y ~/tmp/k230-coherent-boot-board/candidate-home-panel.jpg
Both images were reviewed before committing. They show the remembered Home layout and wallpaper, but do not certify every theme/background option.
Update: the operator accepted the three requested real-finger navigation
checks. The same controller’s baseline/candidate comparison now passes; see
../coherent-manual-comparison/README.md. Persistent installation followed by
an untouched ordinary reboot remains open.
While normal files remain unchanged, reboot from Linux returns to the original
normal boot; --baseline provides the same protected manual fallback. A failed
post-jump kernel that cannot reach serial requires a power reset to that intact
normal path. The controller resets automatically if a load fails in U-Boot.